Peak margin
About 5–6× rated on the 14, 17 and 20 frames, and about 4.2× on the 25 and 32. Size collision loads on maximum torque.
 Home
 Products
CORE FUNCTIONAL PARTS OF THE ROBOT
Robot Joints: Integrated Joint Modules for Robotic Arms
| Parameter | Value |
| Supply | 48 V DC |
| Bus | EtherCAT on the series; CANopen available on select models |
| Safety functions | STO and SBC integrated |
| Safety rating | no PL or SIL certification is published for the module |
| Absolute encoder | 18-bit resolution, ±50″ accuracy, 0.001° repeatability |

| Parameter | Unit | DGMZ14 | DGMZ17 | DGMZ20 | DGMZ25 | DGMZ32 |
| Voltage | VDC | 48 | 48 | 48 | 48 | 48 |
| Rated torque | N·m | 10 | 31 | 52 | 87 | 178 |
| Maximum torque | N·m | 57.5 | 164 | 324 | 363 | 750 |
| Speed at rated torque | rpm | 35.8 | 34.6 | 17 | 16.7 | 16.7 |
| Continuous current | A RMS | 2.1 | 6.3 | 9.2 | 7.05 | 14 |
| Maximum current | A RMS | 6.4 | 18 | 26.4 | 14.1 | 28 |
| Torque constant | N·m/A RMS | 0.11 | 0.083 | 0.102 | 0.14 | 0.22 |
| Weight, T-type | kg | 1.32 | 2.2 | 3 | 3.41 | 8.67 |
| Weight, straight type | kg | 1 | 1.2 | 2 | 3.29 | 5.81 |
Mounting dimensions are drawn per frame size (14, 17, 20, 25 and 32). Reduction ratio, backlash, IP rating, hollow bore and brake option are confirmed in the datasheet with the quote.
Request the datasheet and dimension drawings for the frame you are considering.
Motors, rotors, stators and encoders are built in-house. Drives come from Infranor in Yverdon, acquired in 2020. Five frames cover 10 to 178 N·m rated and up to 750 N·m maximum, as a ready-to-mount robot joint actuator or robot joint motor assembly.
The exploded view shows the frameless torque motor, absolute encoder, harmonic reducer, drive and safety functions on one axis.
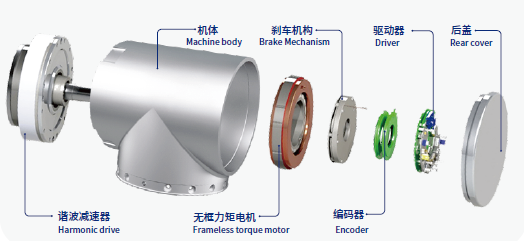
Rotor and stator are built into the joint. Torque constant is 0.083 to 0.22 N·m/A RMS. The standalone frameless torque motor lists 1% torque ripple and 3.5-times overload.
18-bit absolute feedback, ±50″ accuracy, 0.001° repeatability. A standalone time grating absolute encoder for robot joints is also listed.
Cup and hat types are in the wave gearbox range. See how harmonic reducers work in robotic joints and harmonic joint modules for humanoid robots.
Safety rating: no PL or SIL certification is published for the module.
If your machine safety concept requires a certified rating, plan the safety chain around that fact from the start.
The large-hollow low-voltage robot joint driver carries EtherCAT, logic power and safety signals through the center, at 98% efficiency or above.
The compact brake mechanism for robot joints is 9.5 mm thick.
Central-axis routing
No central axis
±50″ accuracy, 0.001° repeatability
Communication bus
Reducer temperature limit
Two derived figures change from frame to frame.
| Derived value | DGMZ14 | DGMZ17 | DGMZ20 | DGMZ25 | DGMZ32 |
| Maximum ÷ rated torque | 5.75 | 5.3 | 6.2 | 4.2 | 4.2 |
| Rated torque per kg, straight type (N·m/kg) | 10 | 26 | 26 | 26 | 31 |
About 5–6× rated on the 14, 17 and 20 frames, and about 4.2× on the 25 and 32. Size collision loads on maximum torque.
10 N·m/kg on the smallest straight frame, 31 on the largest. Keep a distal axis on the lighter frame.
35.8 rpm at rated torque on the 14 frame, 16.7 rpm on the 25 and 32.
Separate parts leave the ratio and motor open. An integrated joint module trades that for one source and five catalog frames.
| Separate parts | Integrated joint module | |
| Suppliers per axis | Motor, encoder, reducer, drive and brake, each sourced and matched | One source for the motor, encoder, reducer, drive and safety functions |
| Wiring | Motor, encoder and drive cabling per axis | Principal motion components share one assembly |
| Envelope | Housings and couplings between parts | Frameless motor in a combined assembly for compact arms |
| Design effort | Validate each joint from scratch | Pick a frame by torque and speed |
| Flexibility | Free choice of ratio and motor | Five catalog frame sizes |
Frames that fall between sizes can be adapted. For a conventional motor, see the servomotor guide and Servomotor Cost: Prices & What Affects Them.
Motors, rotors, stators, clamping systems and encoders.
Infranor Group, Yverdon, Switzerland (acquired 2020).
Robotics core components are within the stated scope of the third Guangzhou factory (2023).
GEM board of the Shenzhen Stock Exchange, code 300503.
400+ R&D engineers.
ISO 9001 quality and ISO 14001 environmental certificates.
Three-stage inspection (initial, specialized, cross), with stated full traceability.
Rotary axes on industrial and collaborative arms, on the same EtherCAT bus as the robot controller (1 ms cycle).
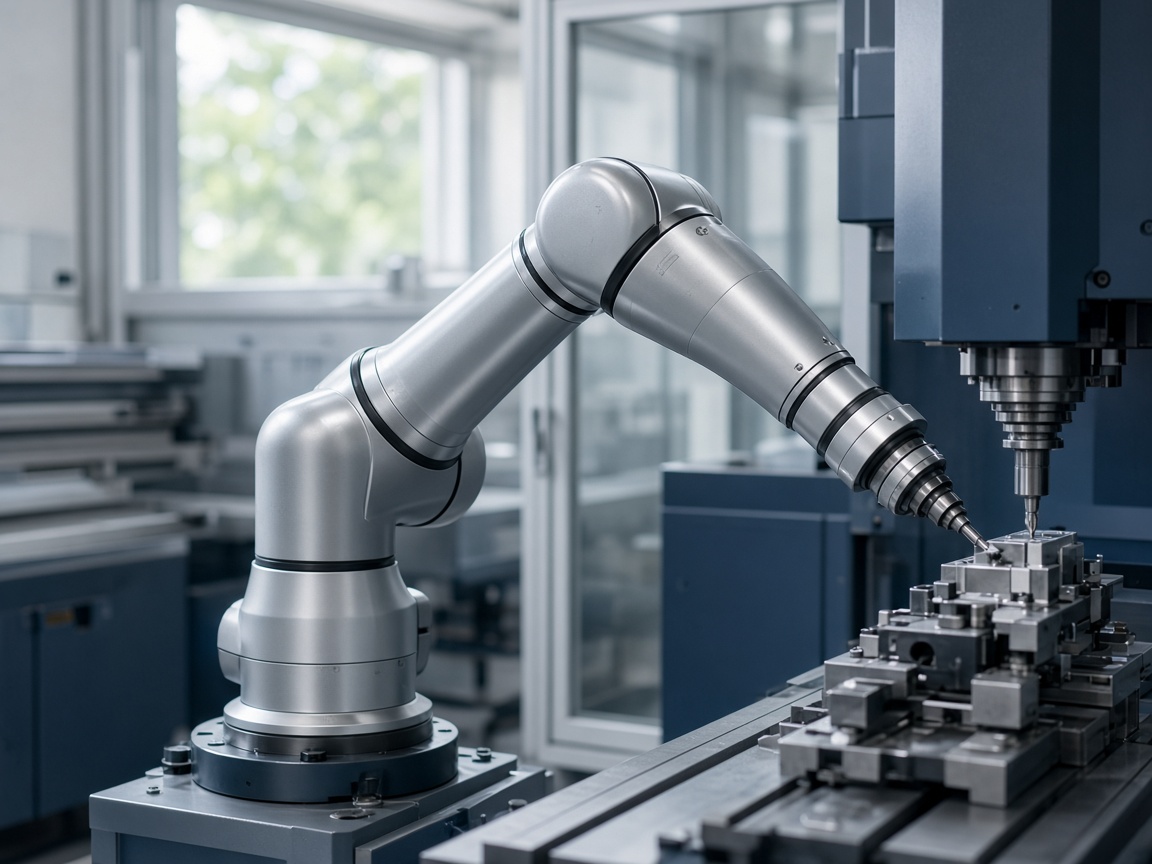
Direct-drive rotary options cover 4th-axis tables. 5 Axis Rotary Tables for CNC Machining cover tilt-rotate positioning.
For a gantry or track, see Linear Rail Explained: The Complete Guide, the motor guide and linear motor cost.
If the arm carries a motorized spindle, what is a spindle explains the selection logic.
Rated 10 to 178 N·m, maximum 57.5 to 750 N·m. Larger frames sit toward the base of the arm.
16.7 to 35.8 rpm at rated torque.
Central-axis routing is ±360°. Without a central axis, rotation is infinite.
48 V DC and EtherCAT. Ask if you need CANopen.
Decide if the axis needs a brake. STO and SBC are integrated.
1 to 8.67 kg, T-type and straight type.
Send torque, speed, bus, supply, routing, brake and envelope with the enquiry. An application engineer matches a frame, flags what would need adaptation, and you receive a quote. Pricing, minimum order quantities and lead times are confirmed per project.
Looking for robot joints for sale? Request a quote with your axis requirements, or talk to an application engineer about frame selection.
Request Now


+86 (20) 6225 7588 ext. 8558
No. 68 Hefeng Road, Huangpu District, Guangzhou, Guangdong Province, China, 511356
